top of page

3-Axis Gimbal
This currently planned 3-axis gimbal will hopefully be a big stepping stone in my progress, allowing me to integrate many different electronics and 3D printed parts into a self stabilizing gimbal.
Project type
Mechatronics
Date
August 2026
Location
Columbia, MO

01
3-Axis Gimbal
01
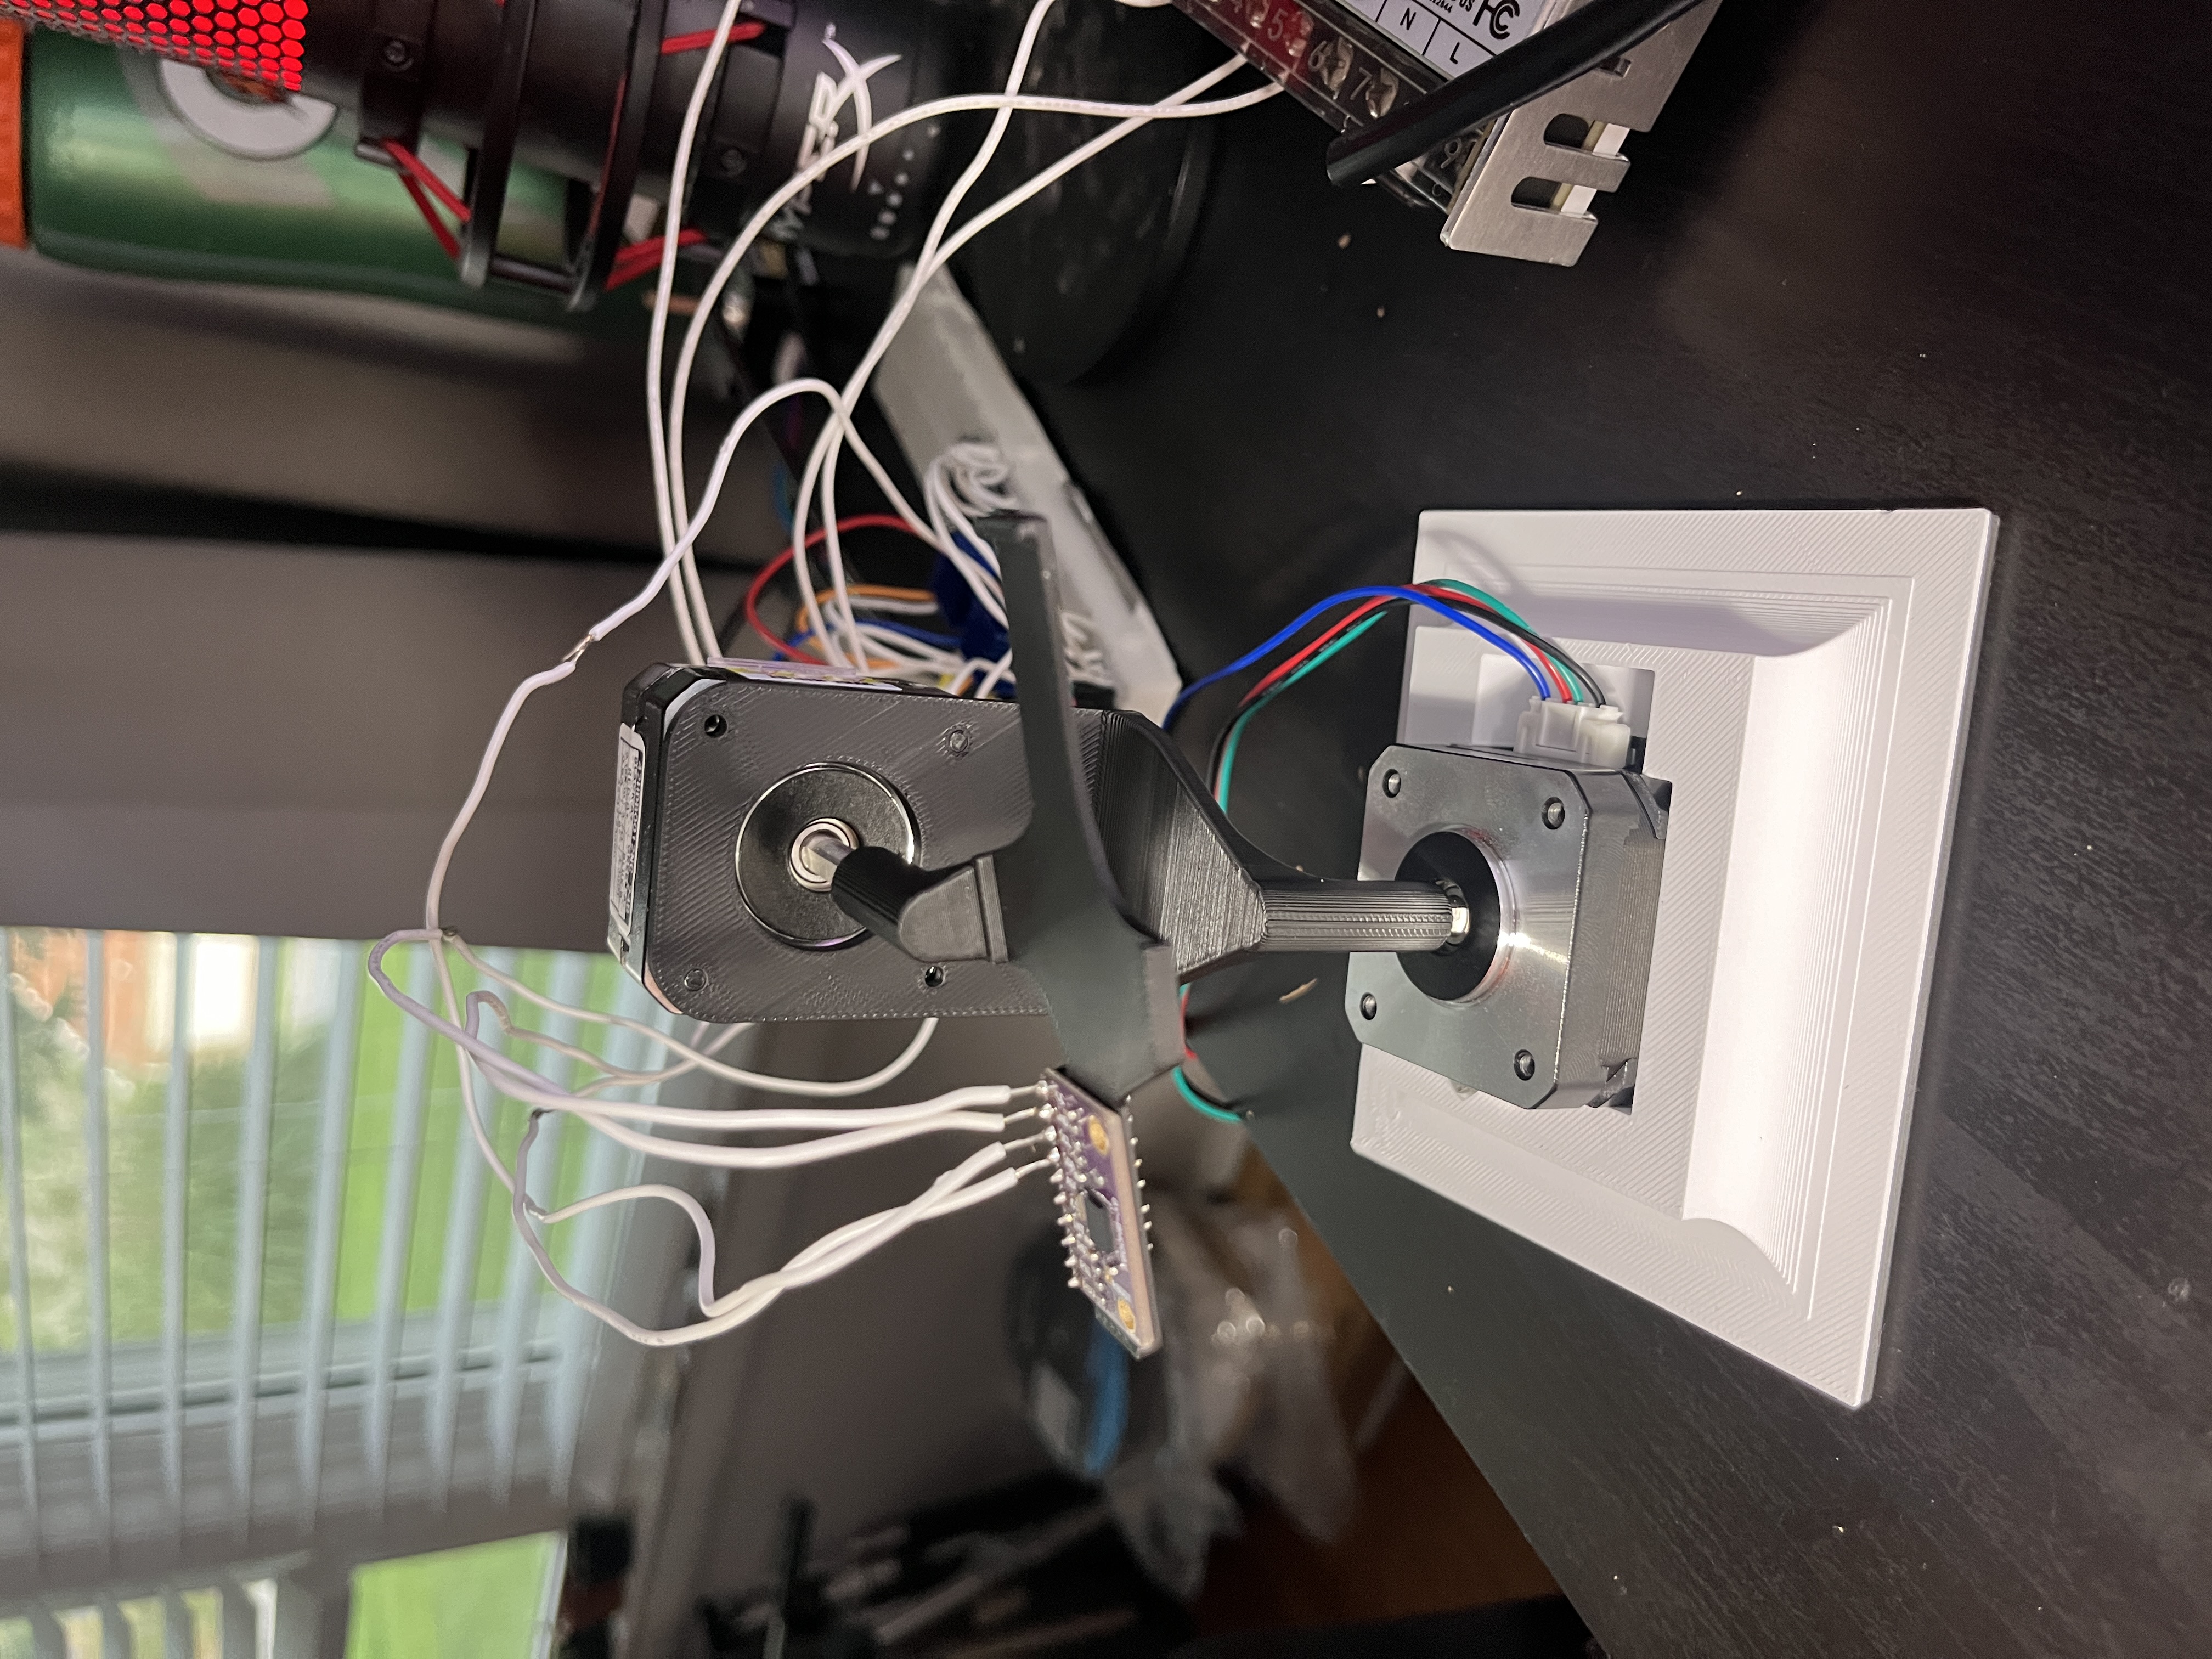
2-Axis Gimbal

02
IMG_5942

03
IMG_5940

04
IMG_5933

05
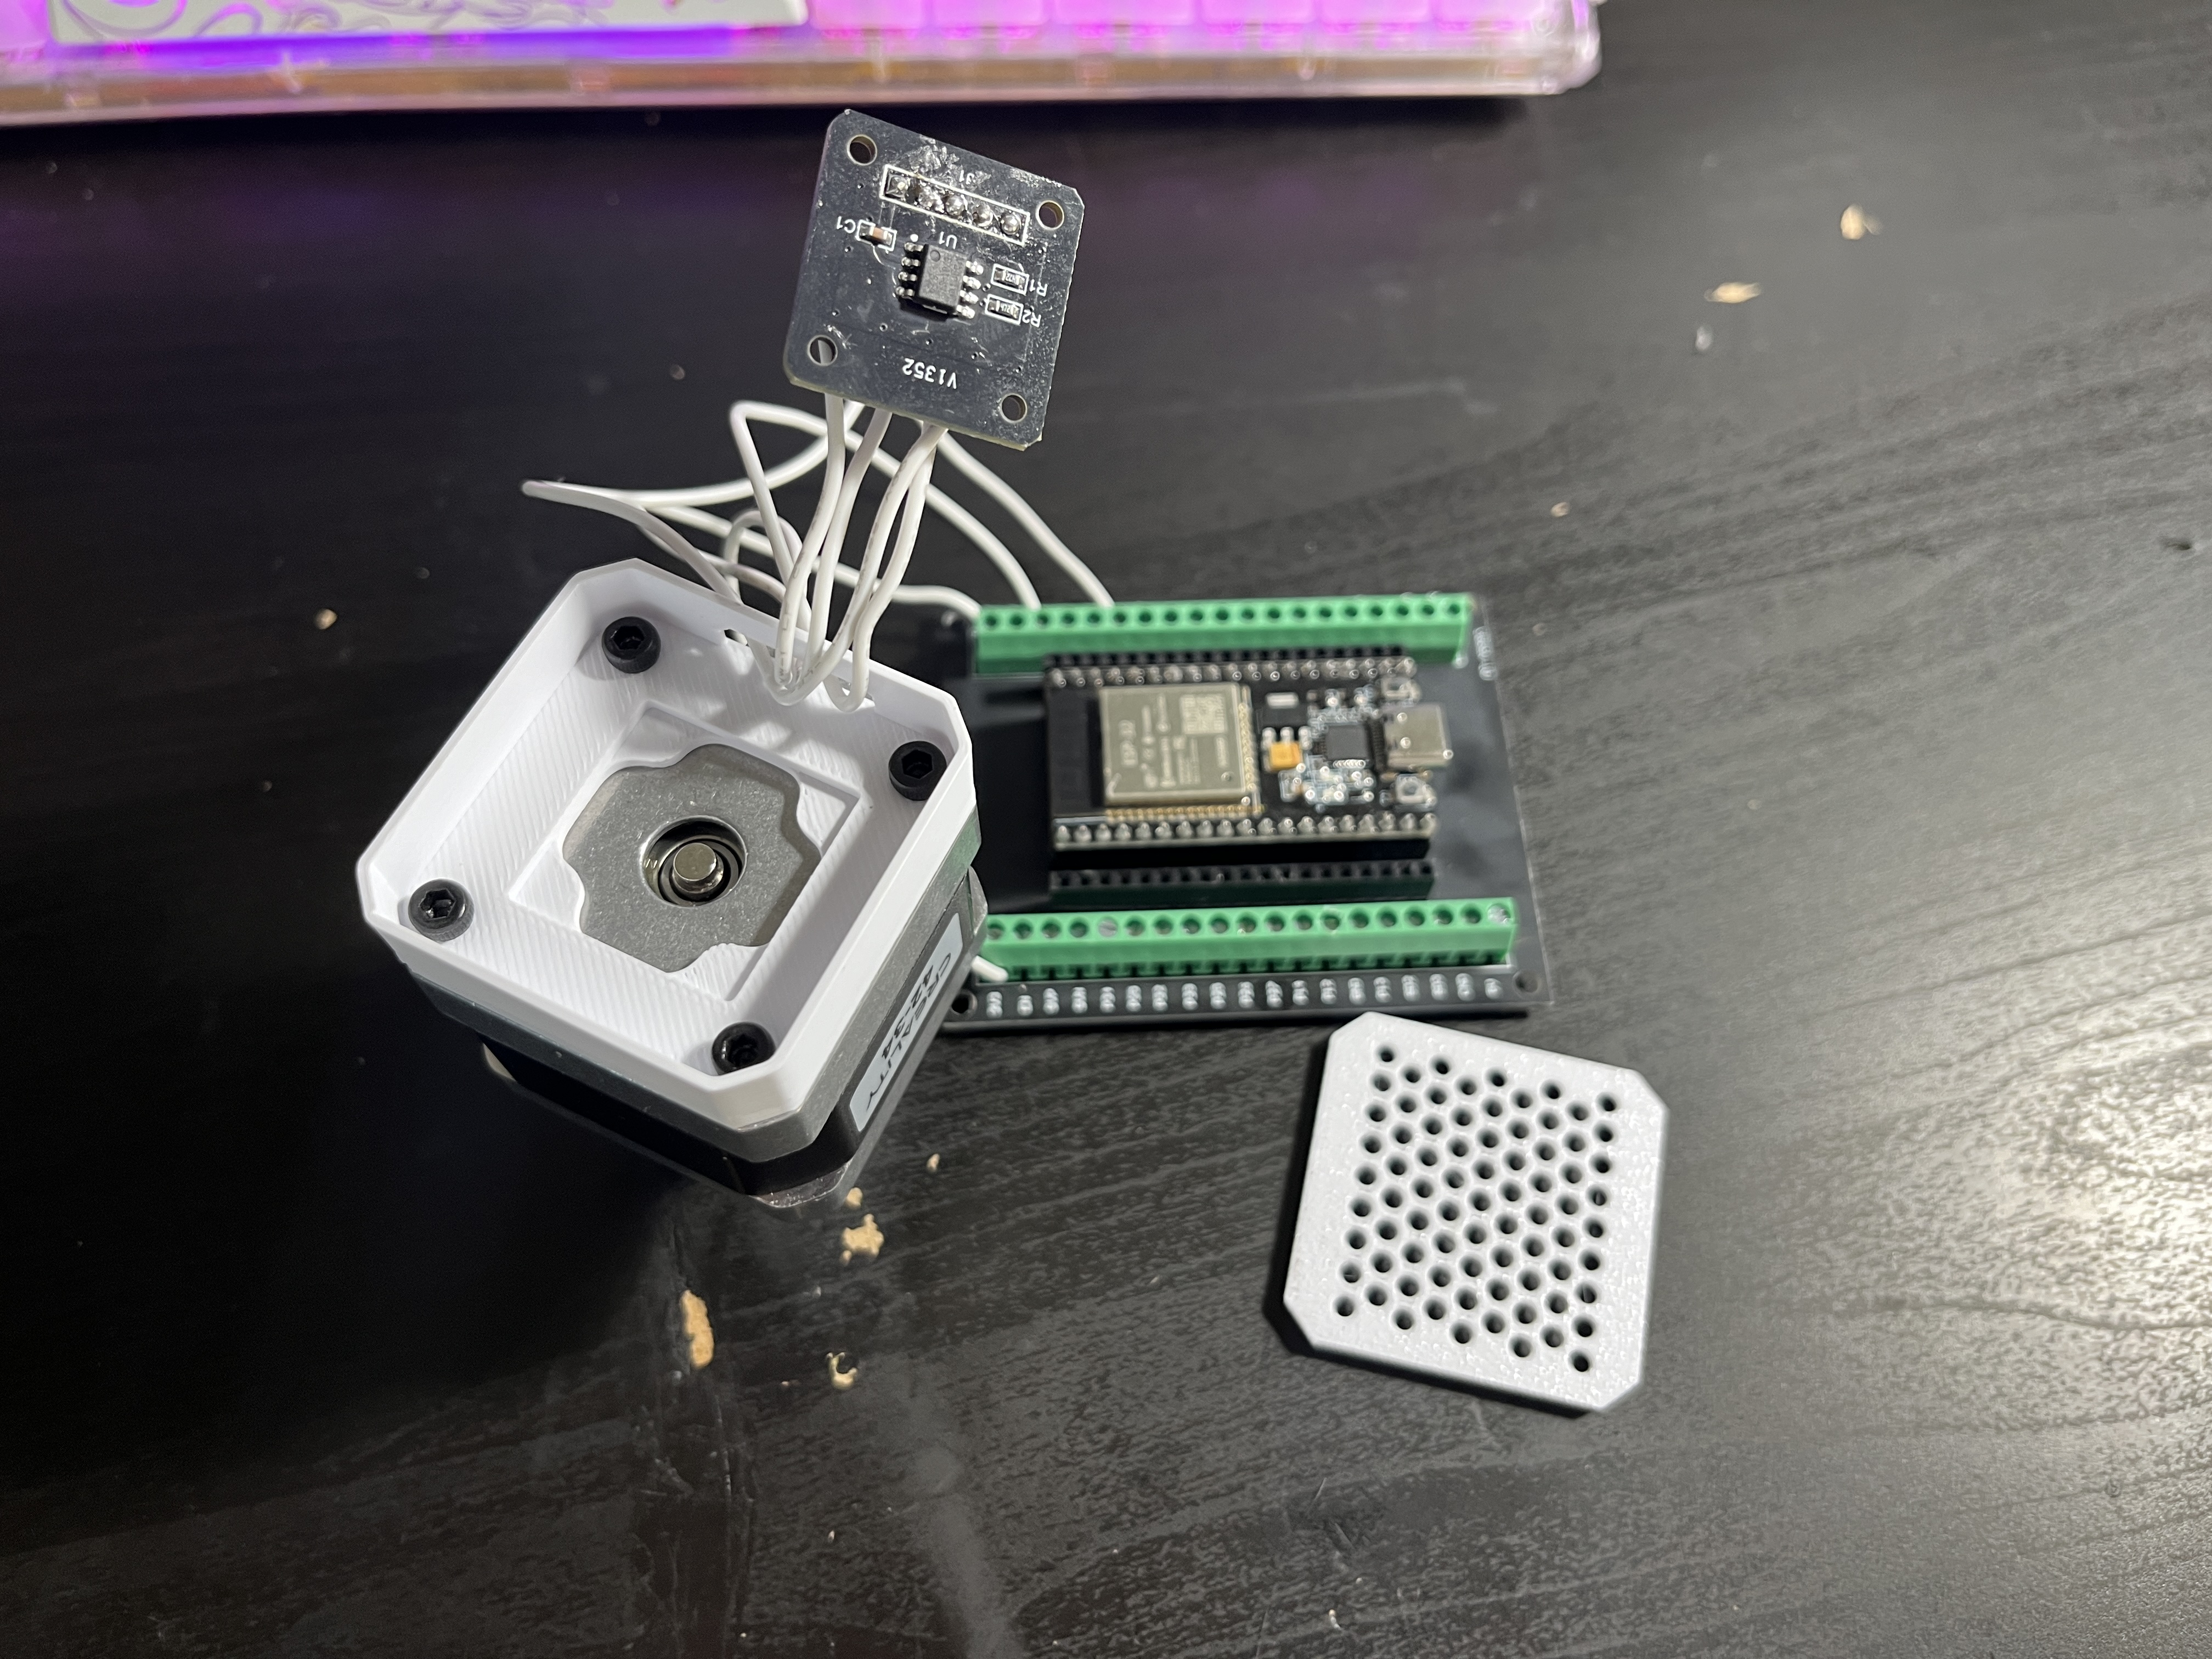
Self made Closed Loop Stepper Motor
I want this gimbal to be precise, so making sure I know the angle of each axis quickly is important. One of the big issues with stepper motors, among other things, is that they don't know where they are. This makes it hard to determine the precise angle of each axis.
06
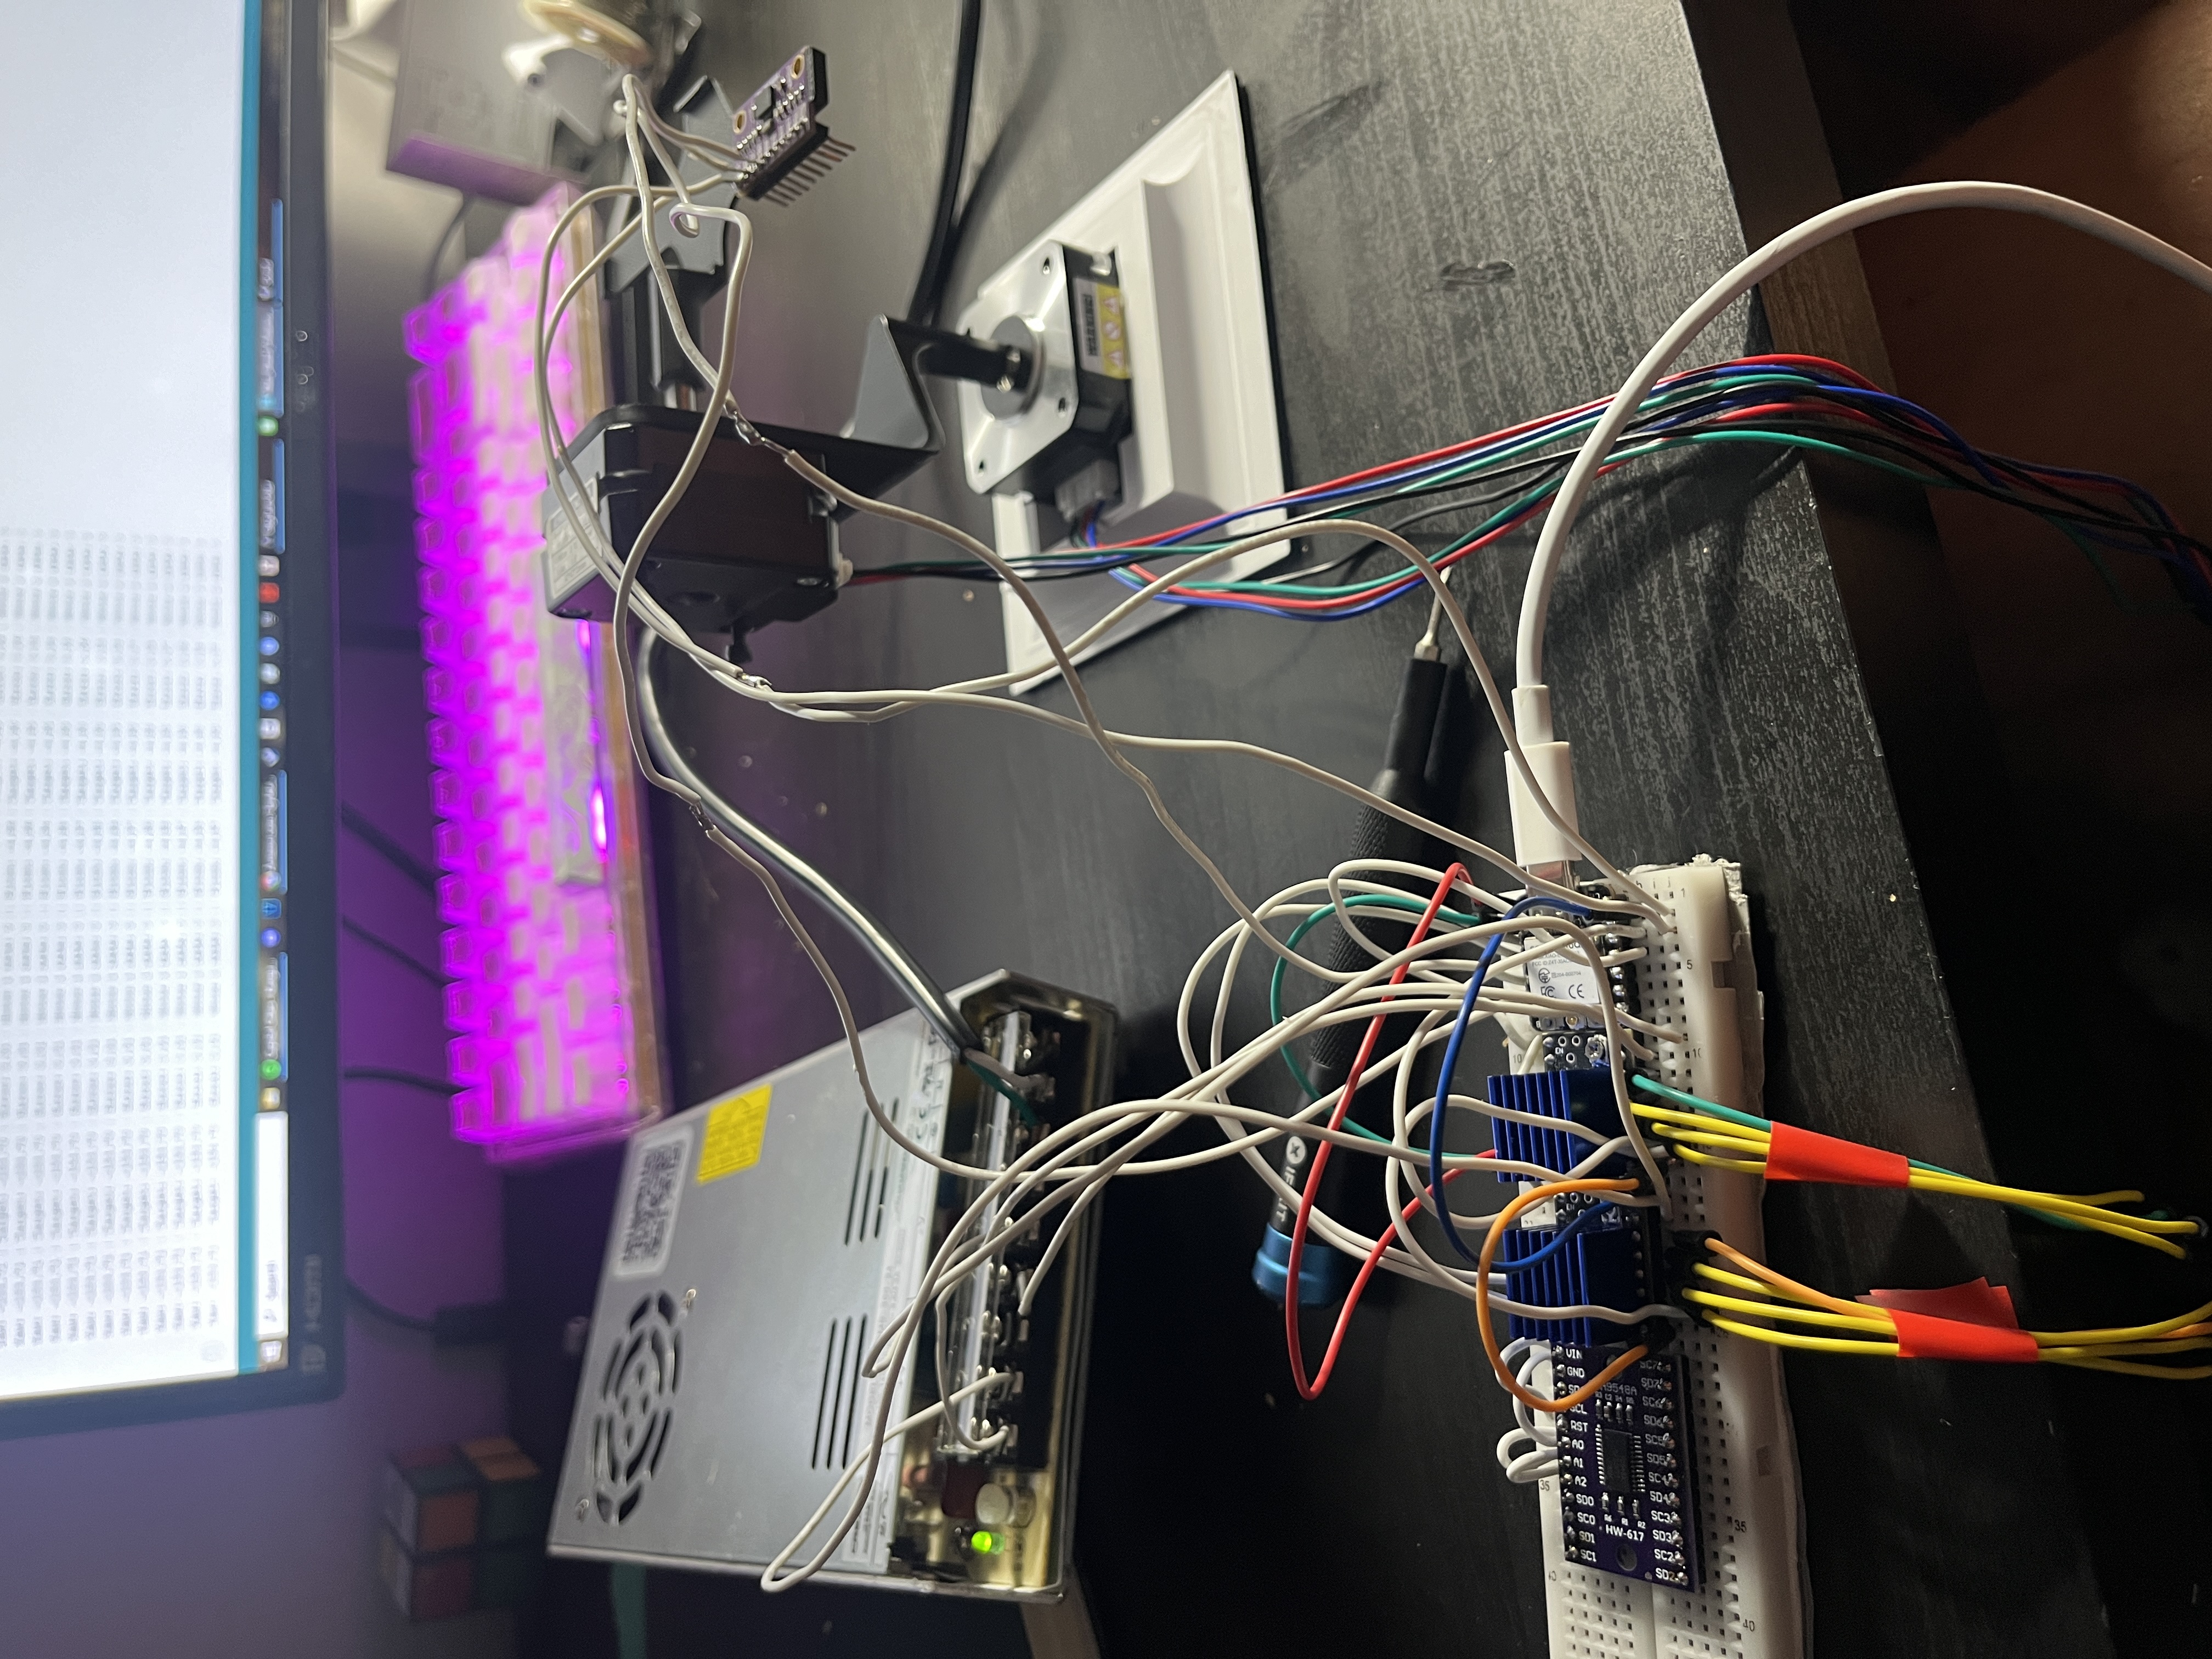
Encoder Working over I2c
Here is the real time sensor data from the encoder to my computer using an esp32. Compared to the alternative being PWM/ analog I2c is way faster and way more accurate.

07
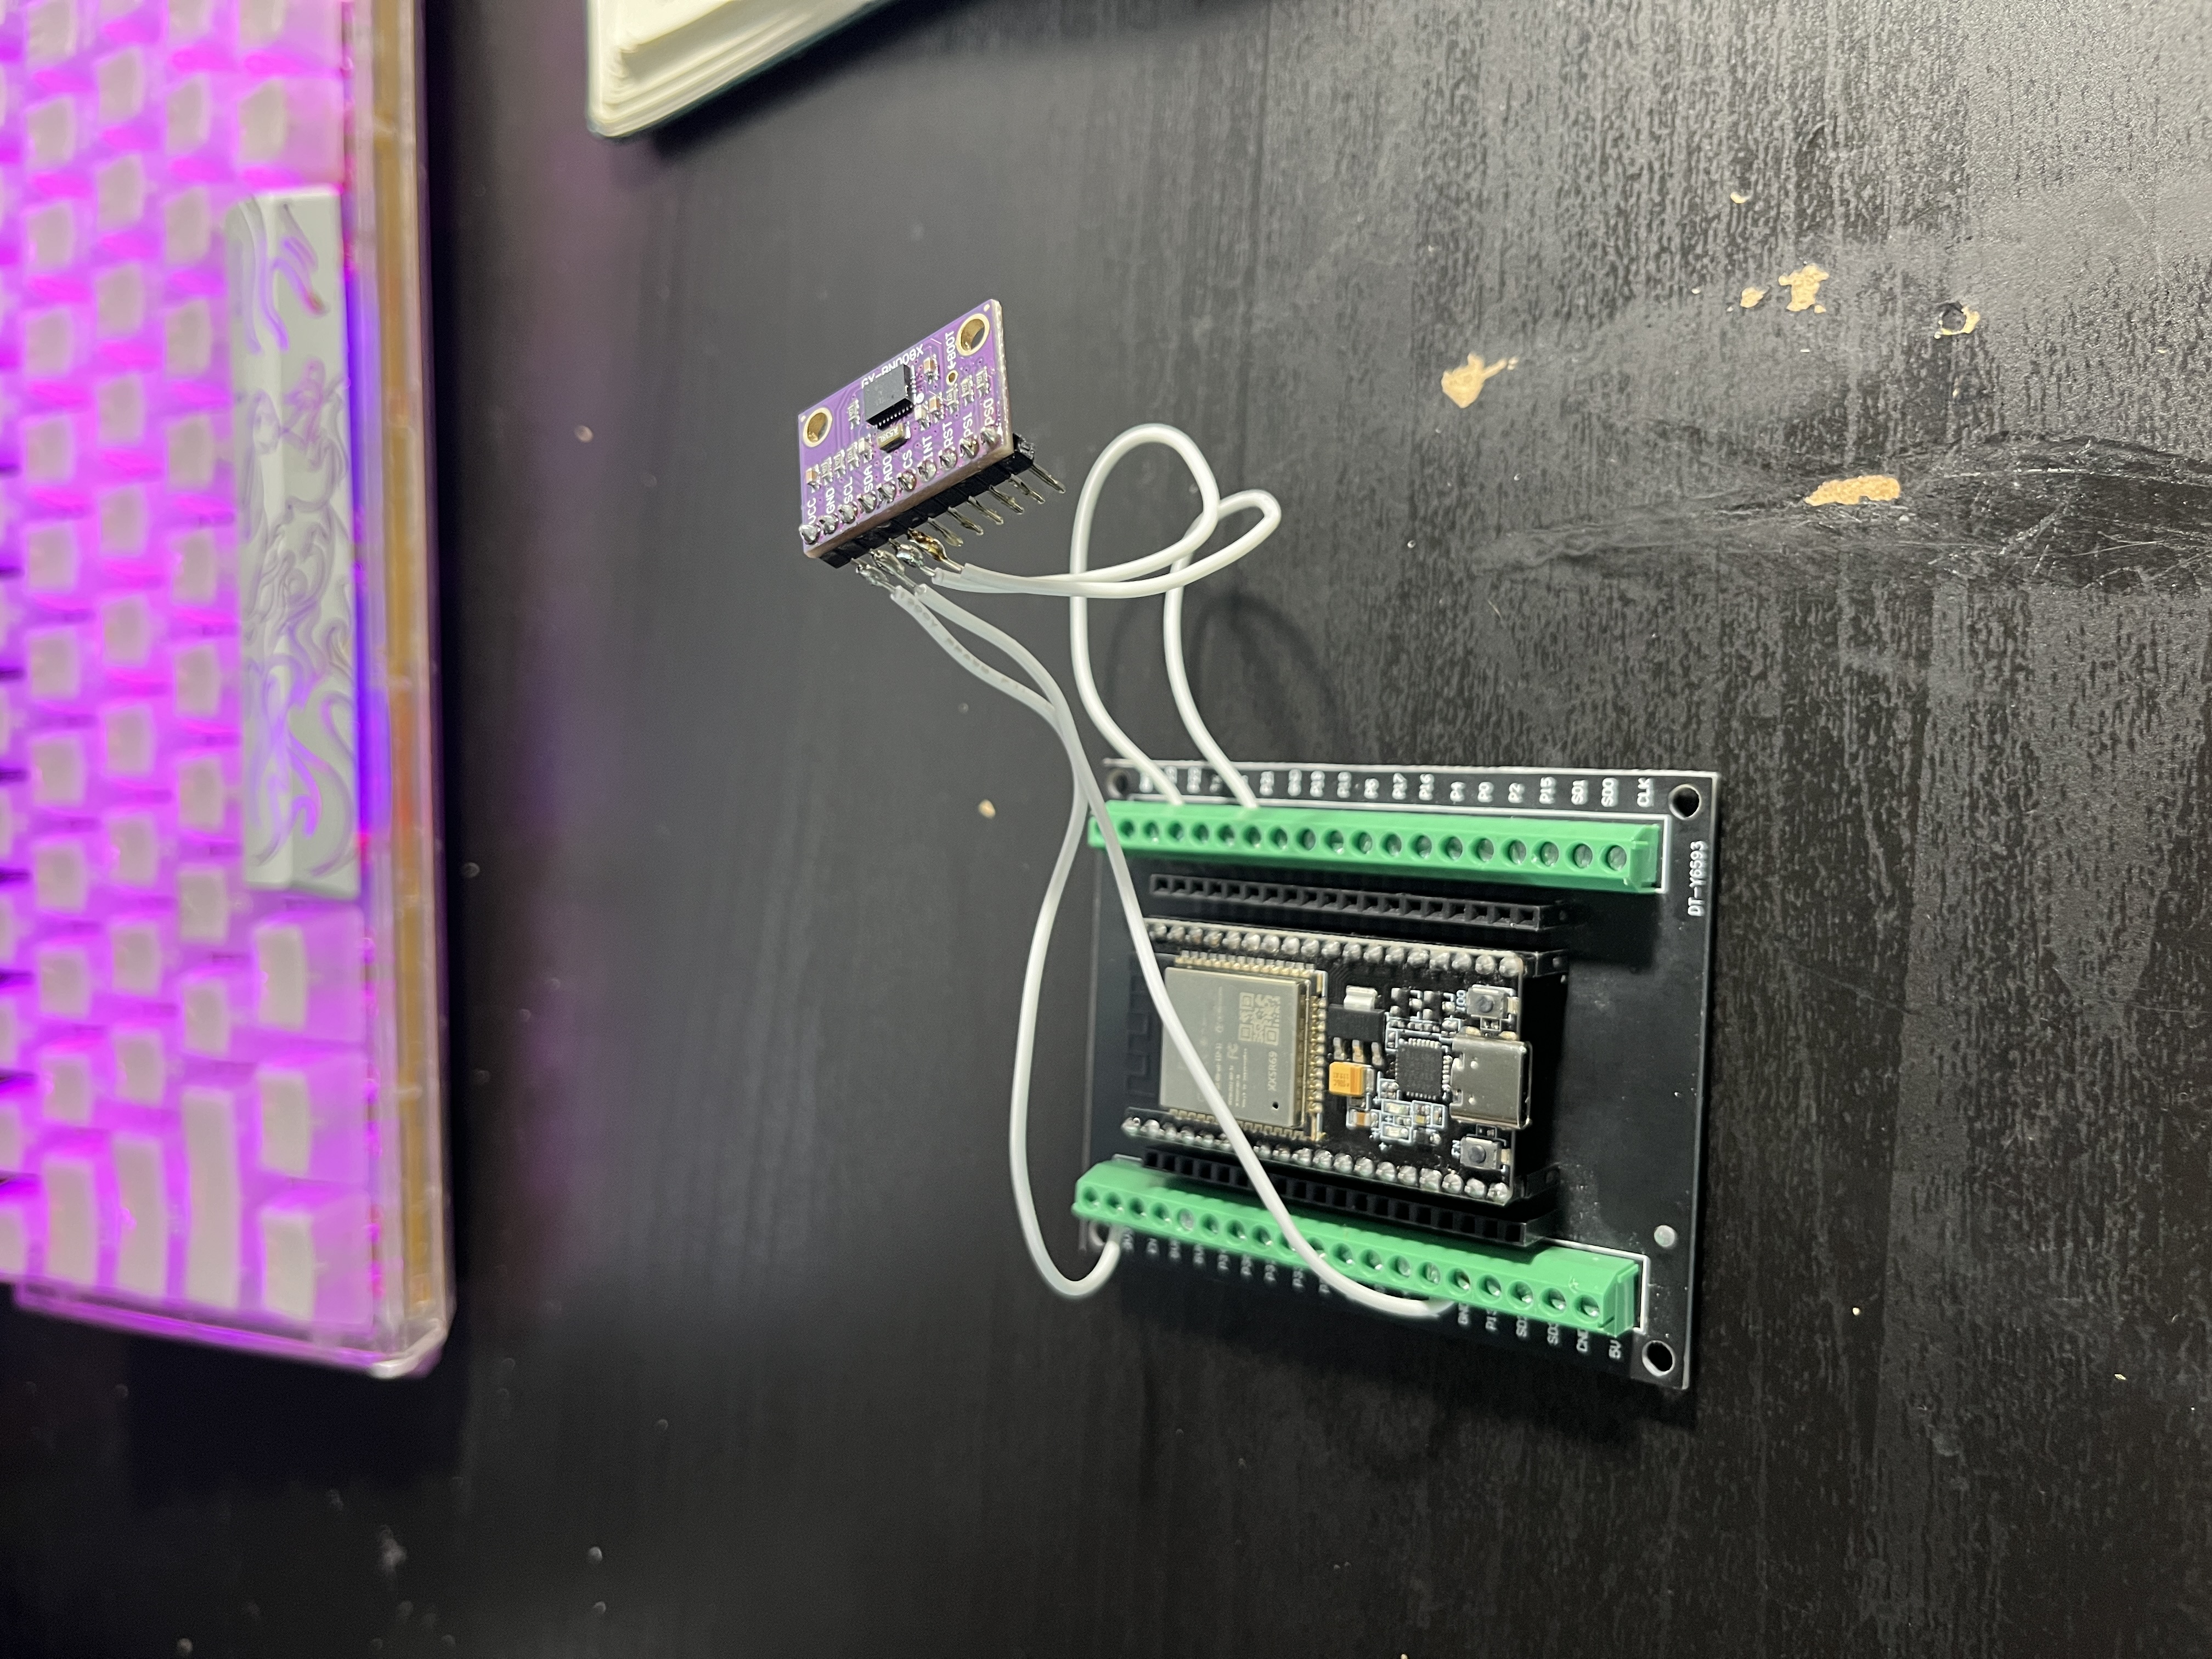
Gimbal IMU
This IMU, speaking over I2c, will convey all its sensor data to the ESP32. I'm hoping this system will work well as a way to get a precise and well working gimbal.

08
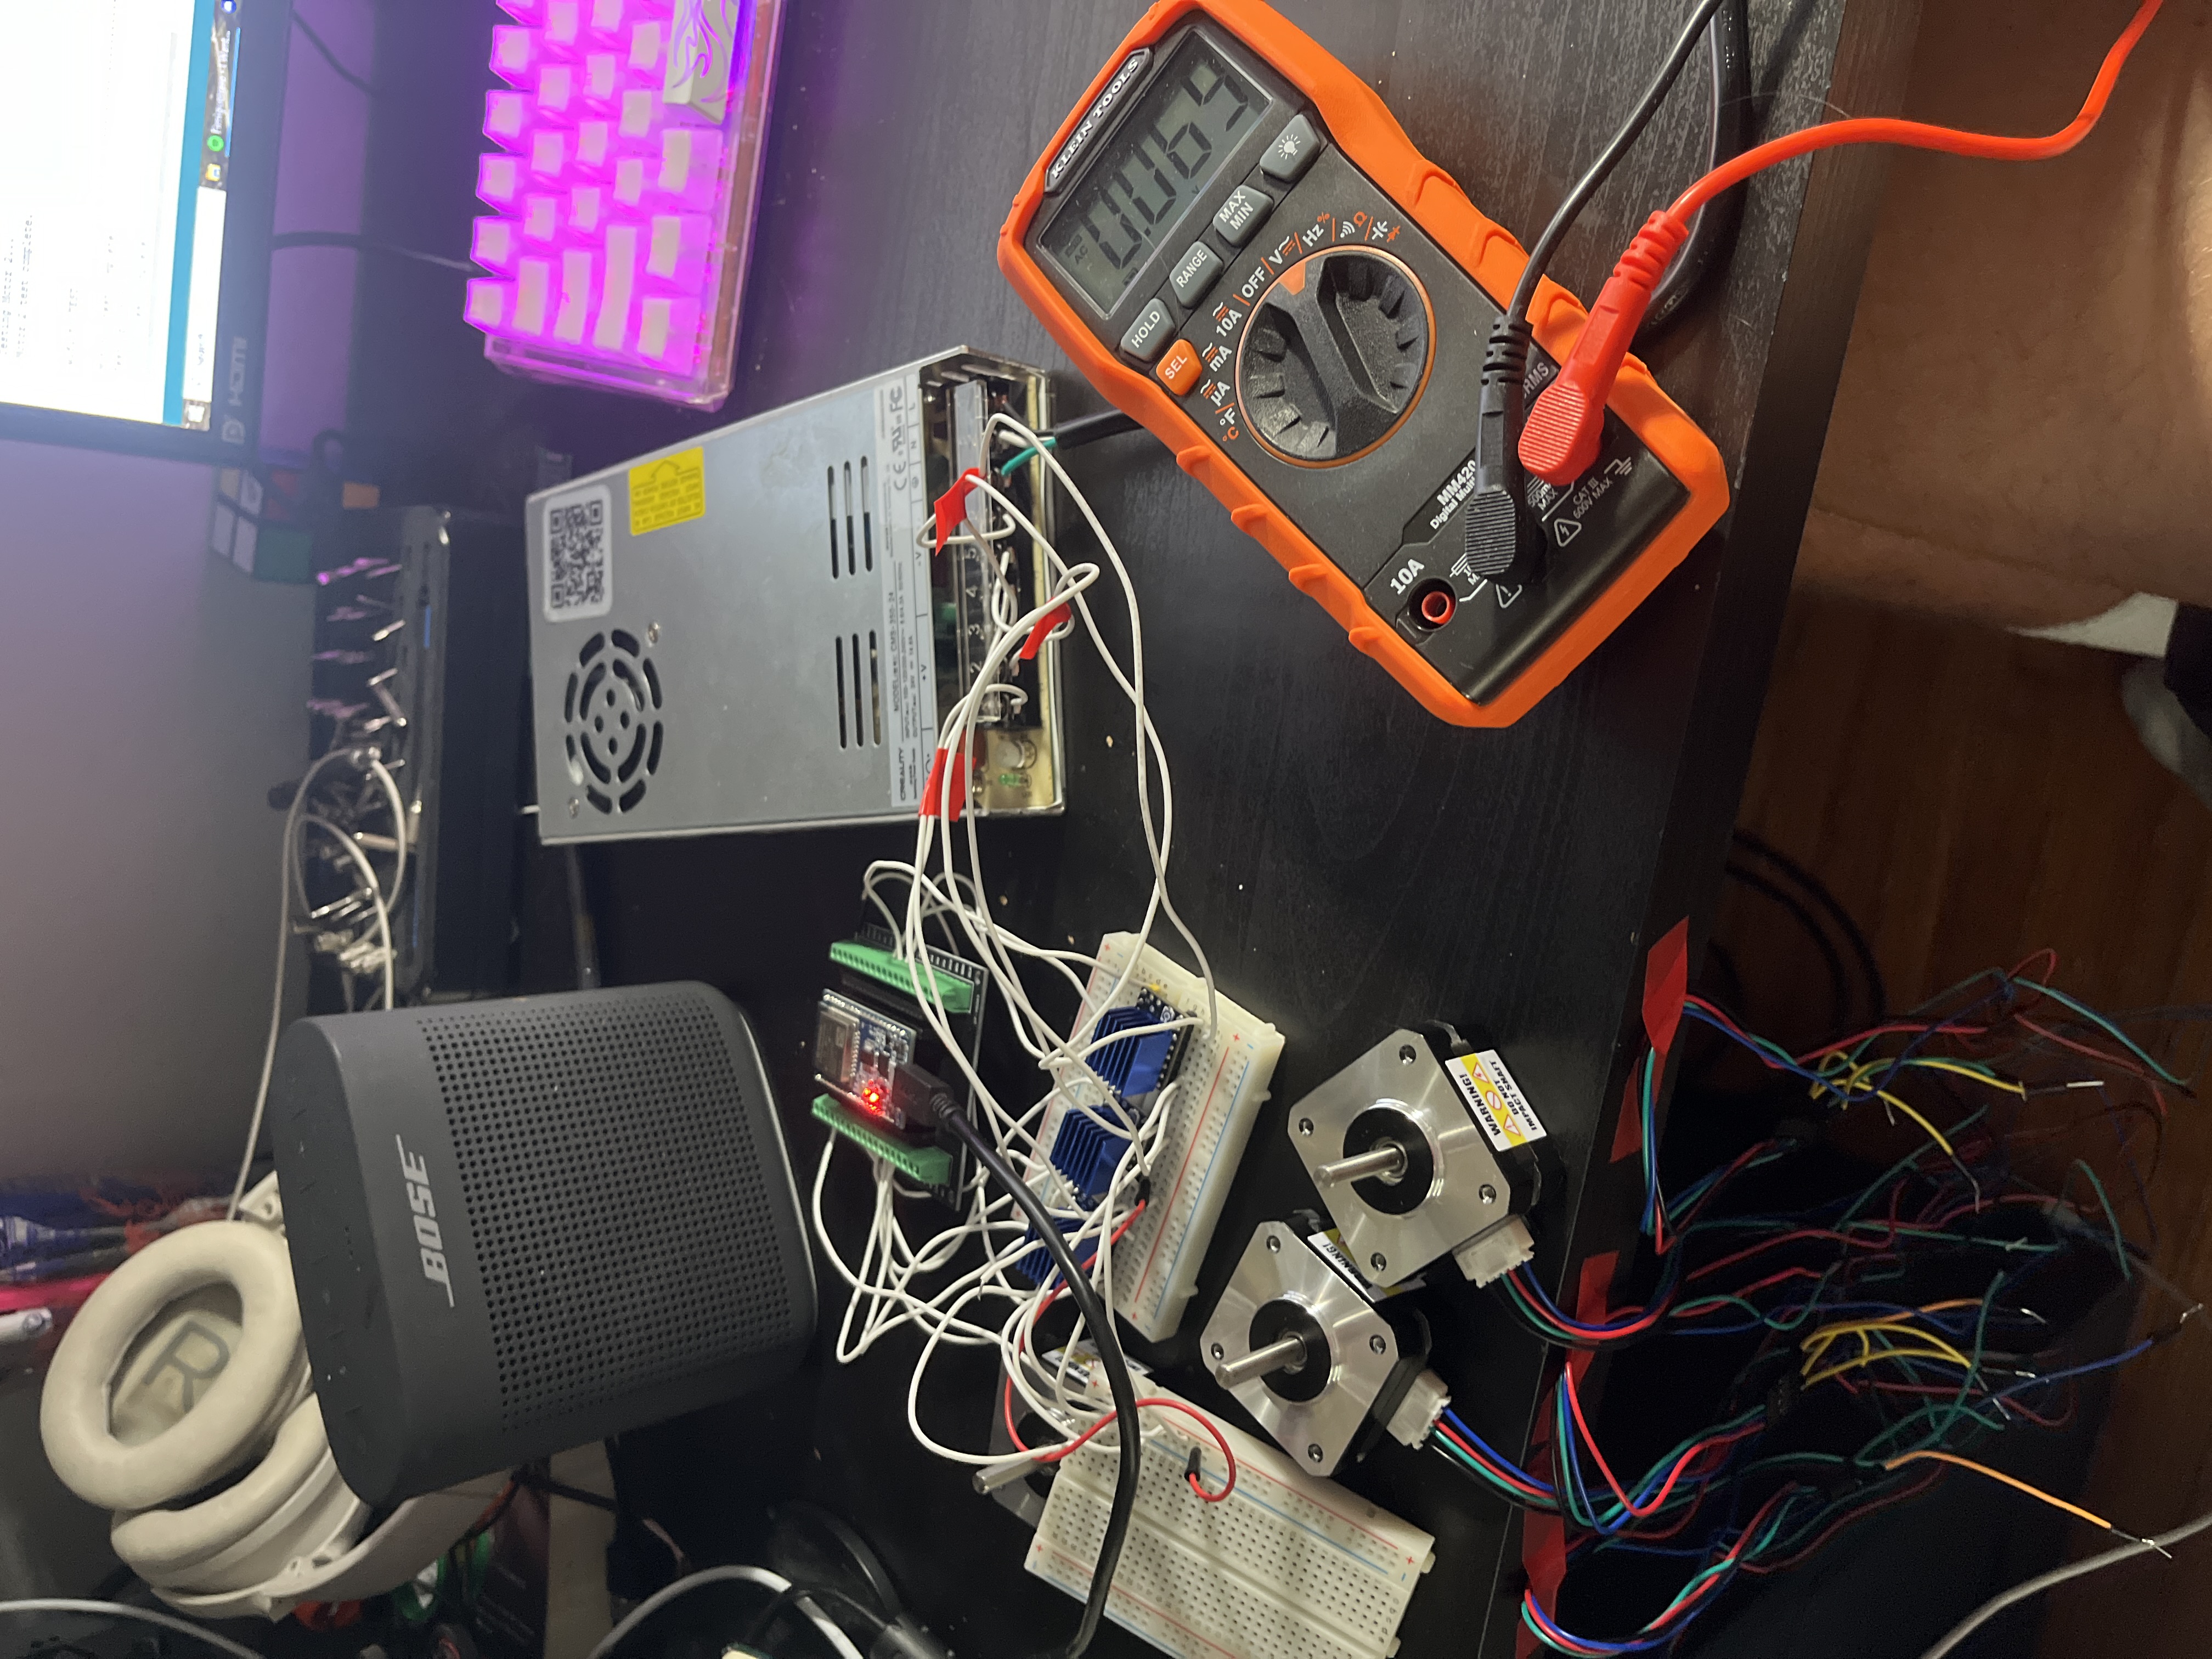
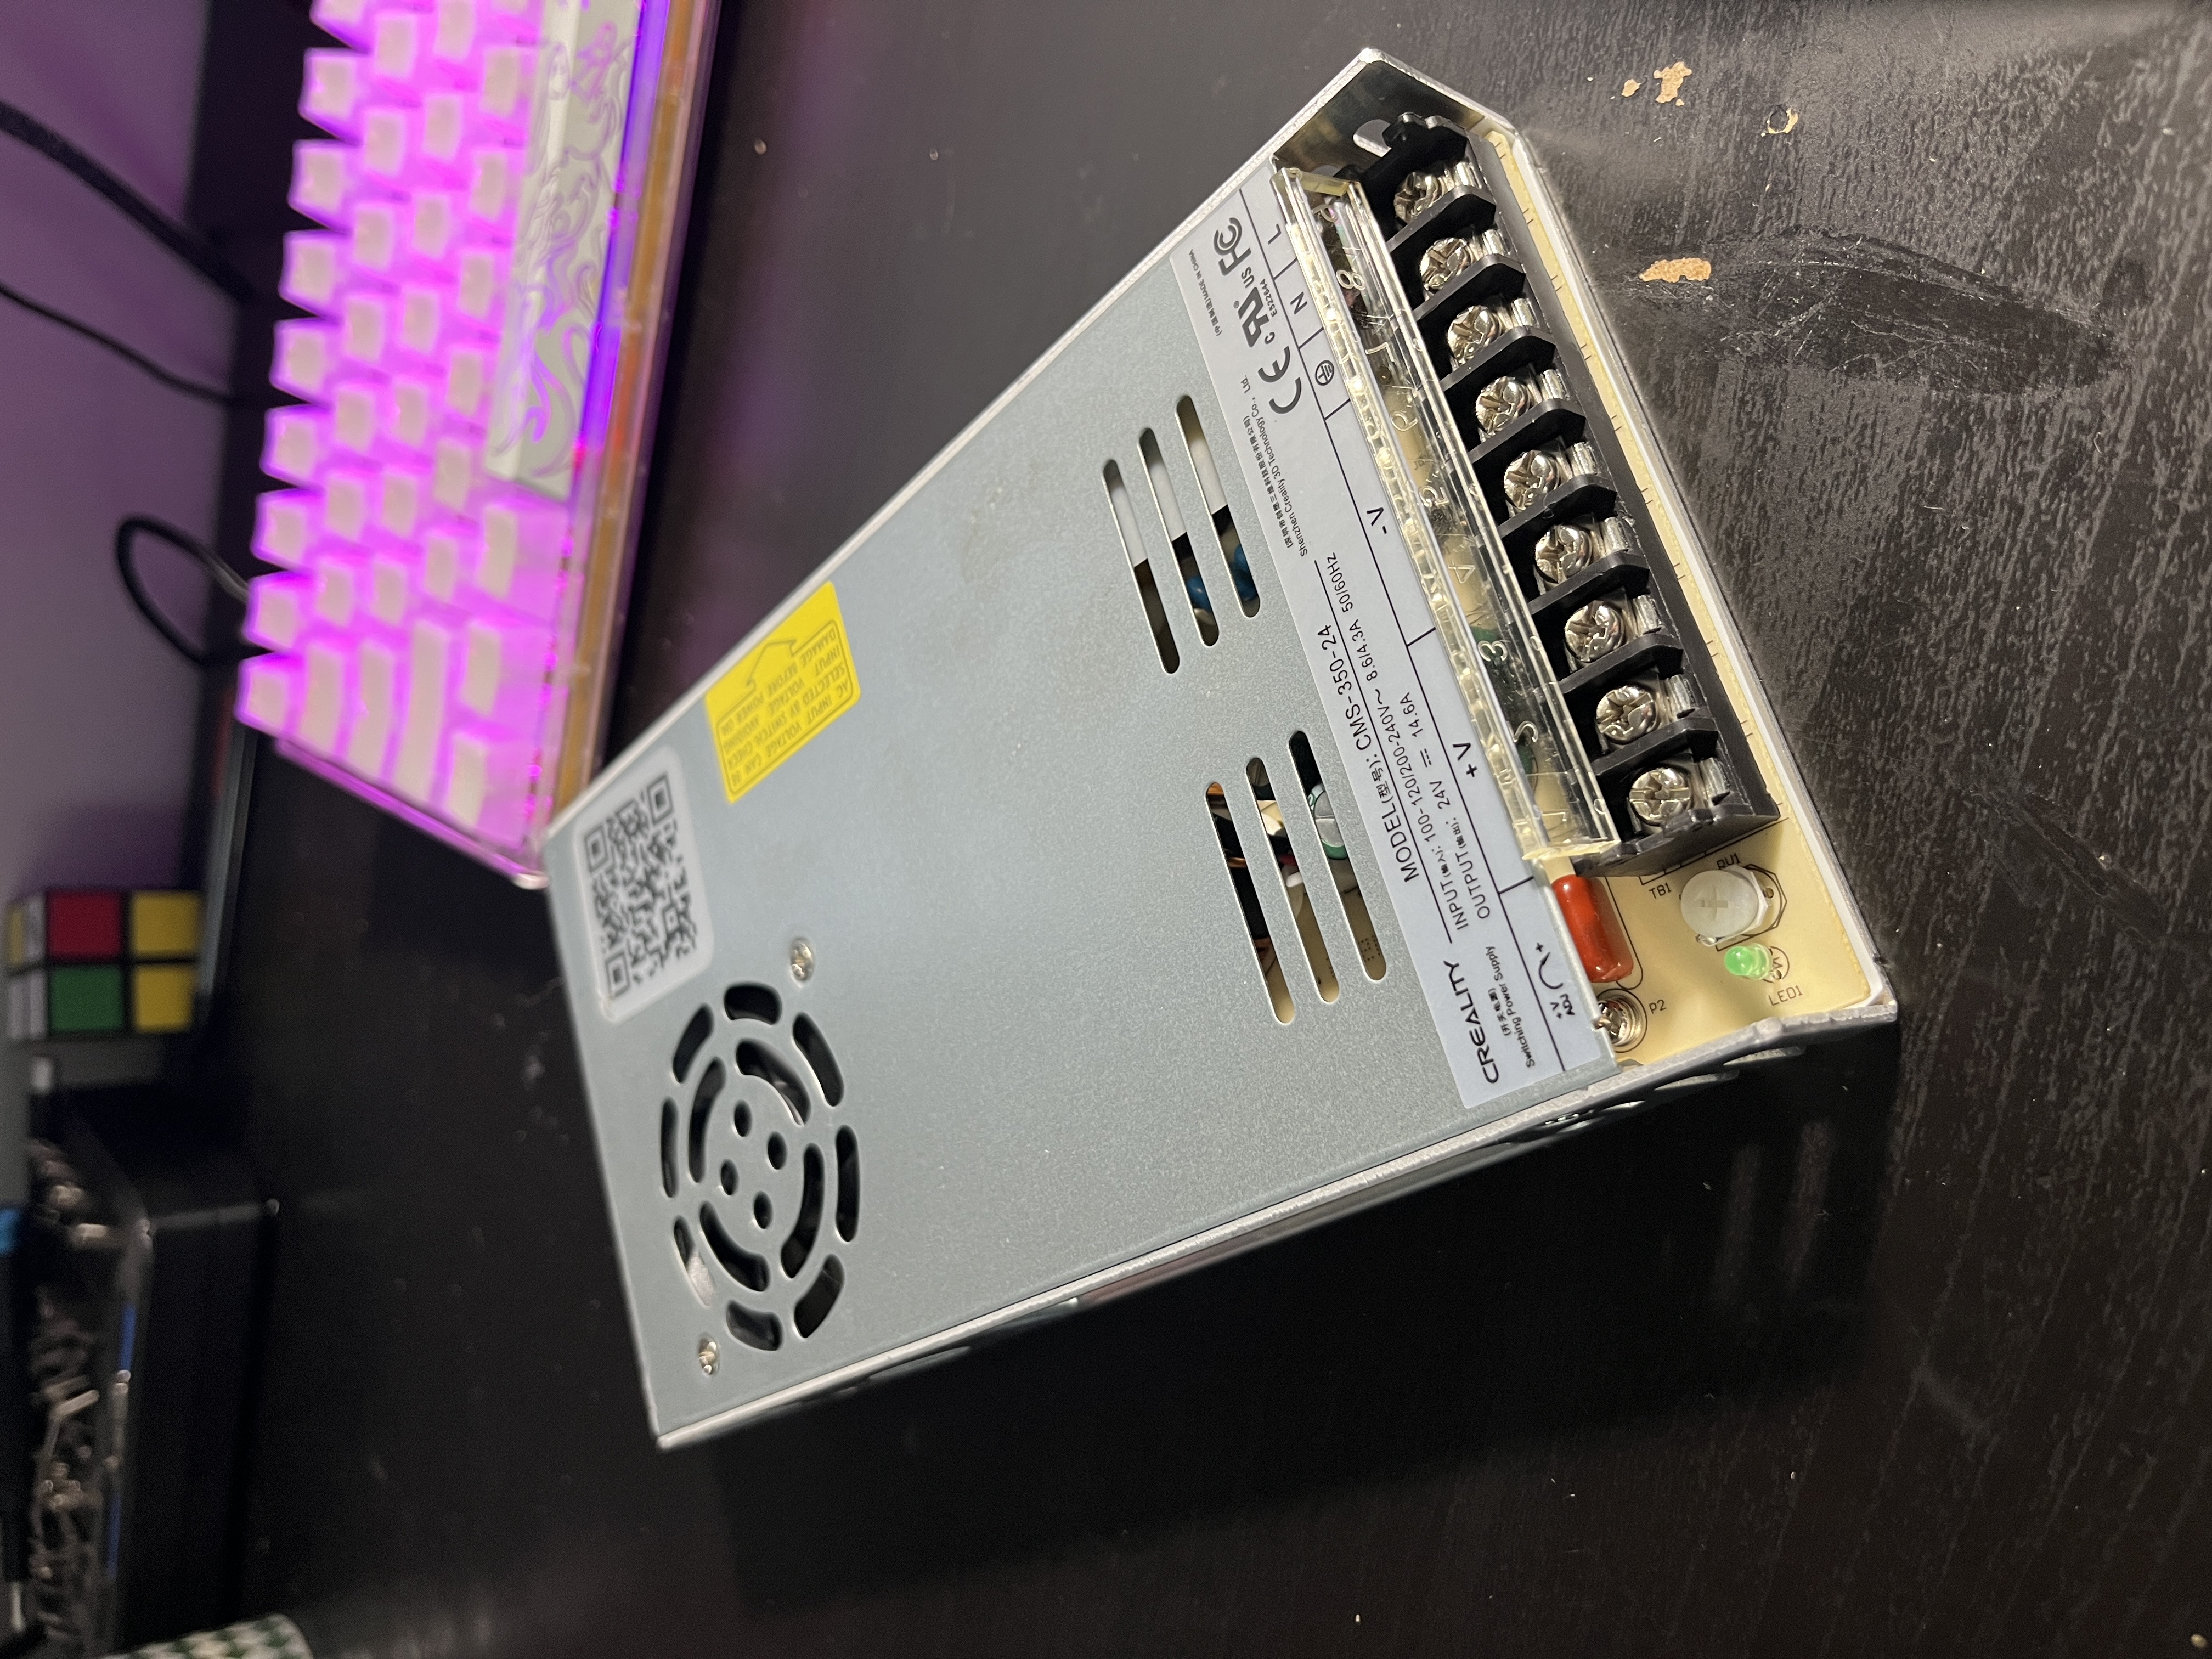
Test Gimbal PSU
This will be the power supply for the mean time, before maybe I make this whole setup battery powered or a better supply. I acquired this power supply from an old ender 3 that I tore down.
bottom of page